Field notes
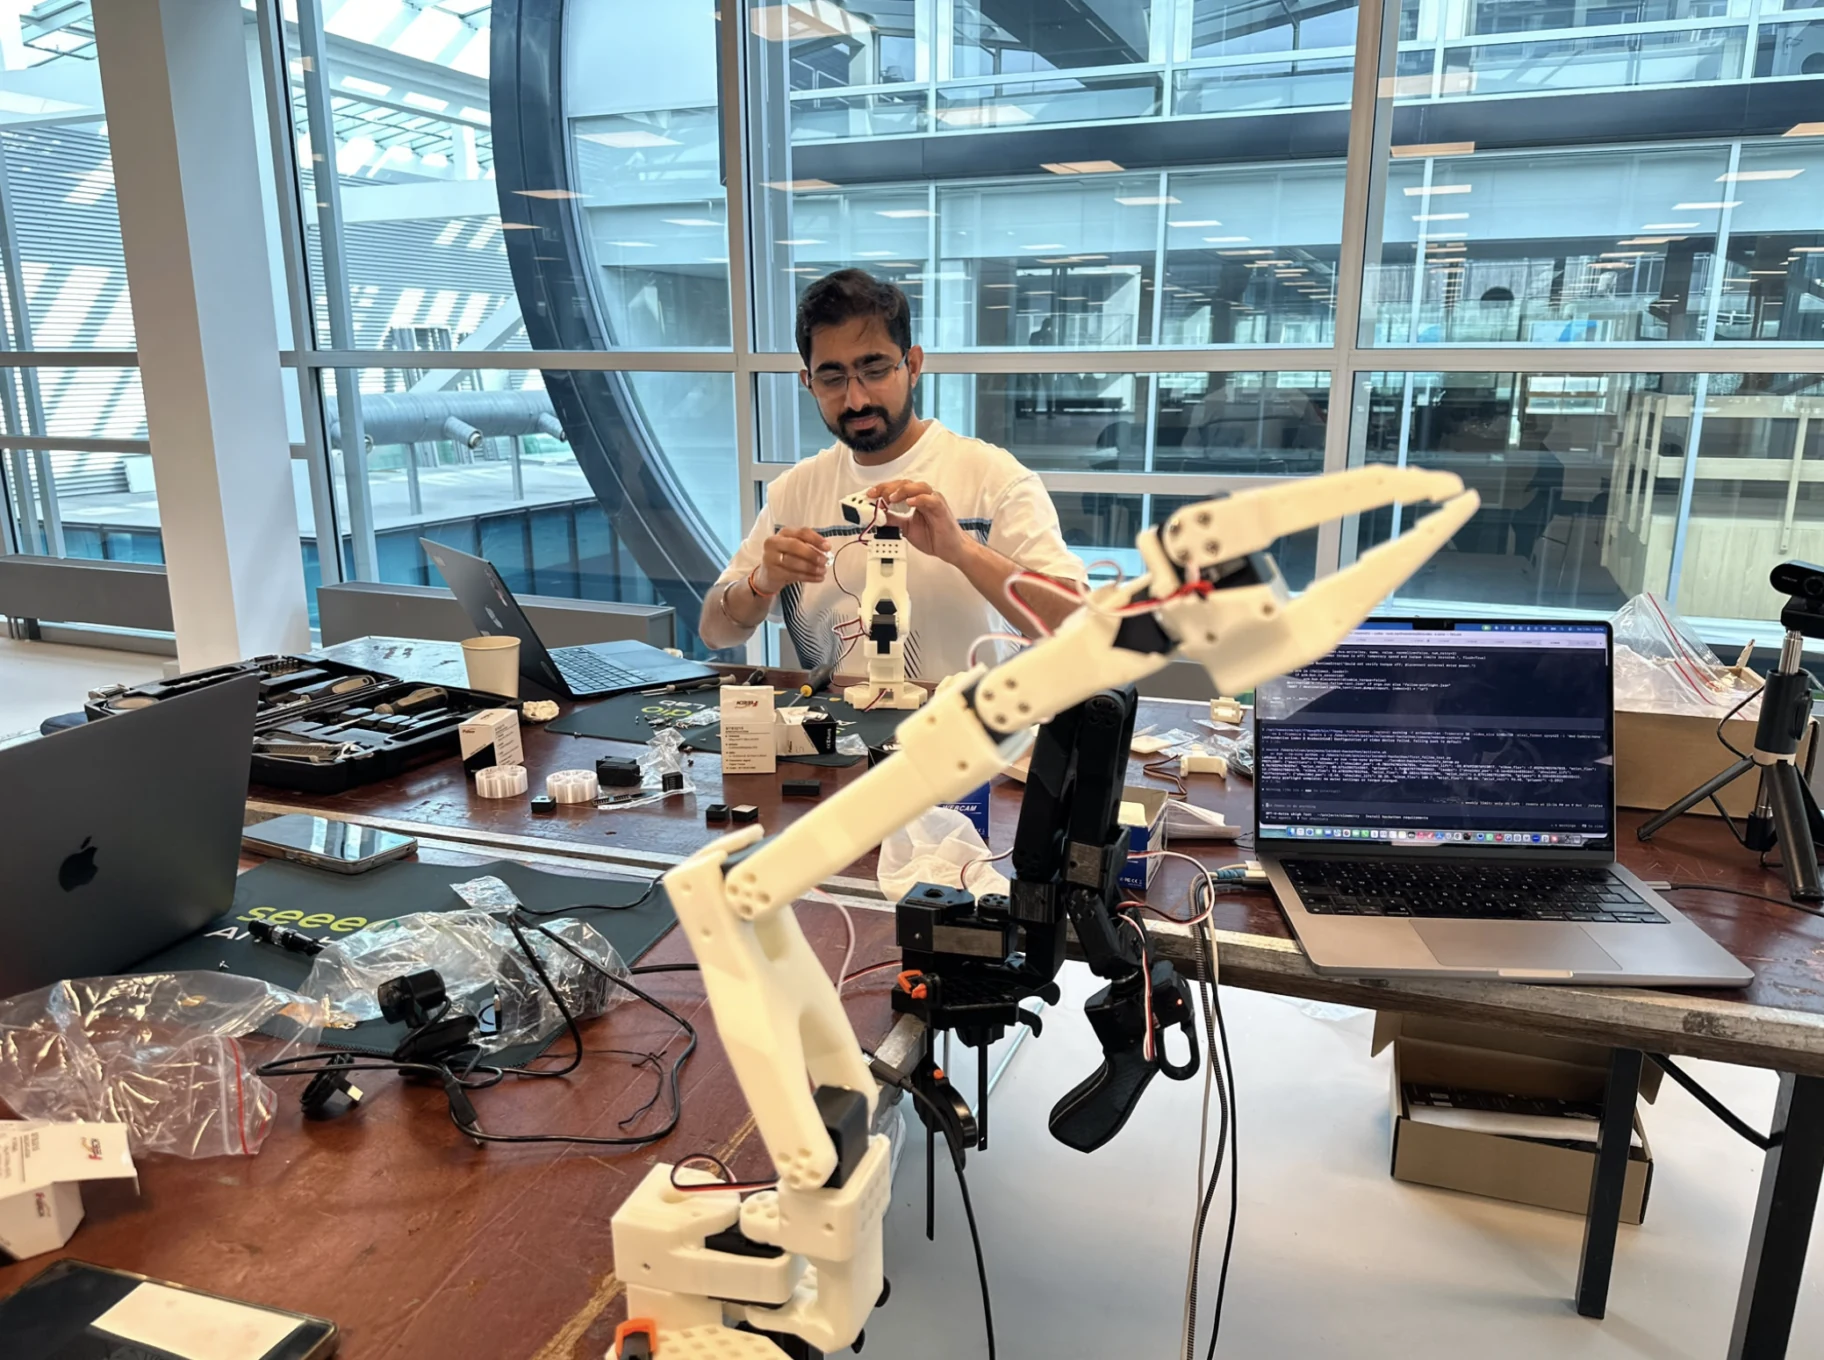
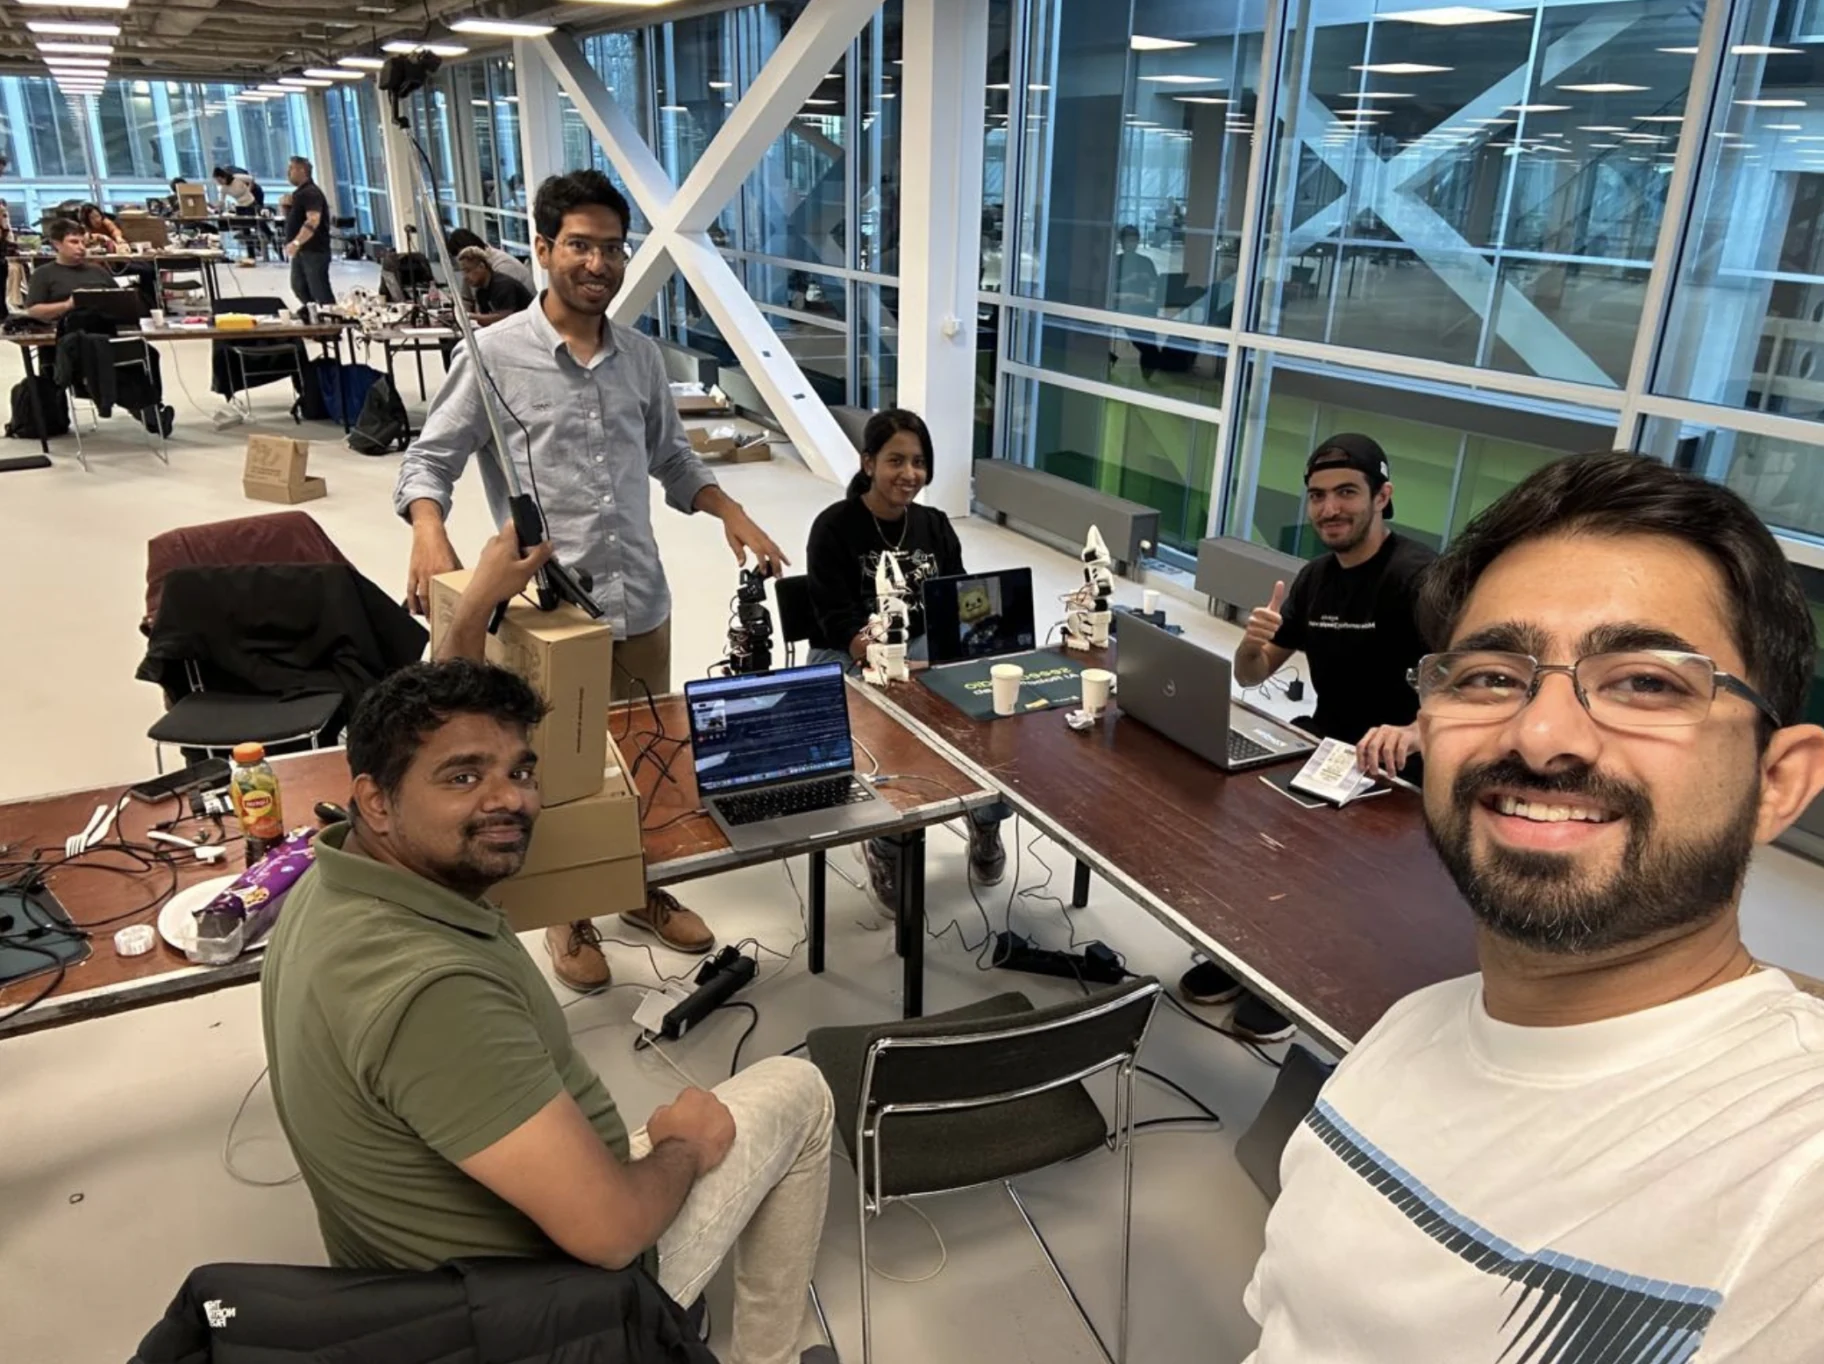
Building Mizu with SO-101 arms: ClawMetry at La Machine
A firsthand account of Mizu, the Healthy Desktop prototype, with original team photos and the historical ClawMetry dashboard.
 ClawMetry
Real builds, inspectable evidence, and the questions we are still working through. Follow the work from SO-101 arms in Amsterdam to a remote robot pilot and the next hackathon.
Field notes
A firsthand account of Mizu, the Healthy Desktop prototype, with original team photos and the historical ClawMetry dashboard.
Developer guide
An evidence checklist for the SO-101 workflow, from calibration context and camera freshness to a useful saved run.
Developer guide
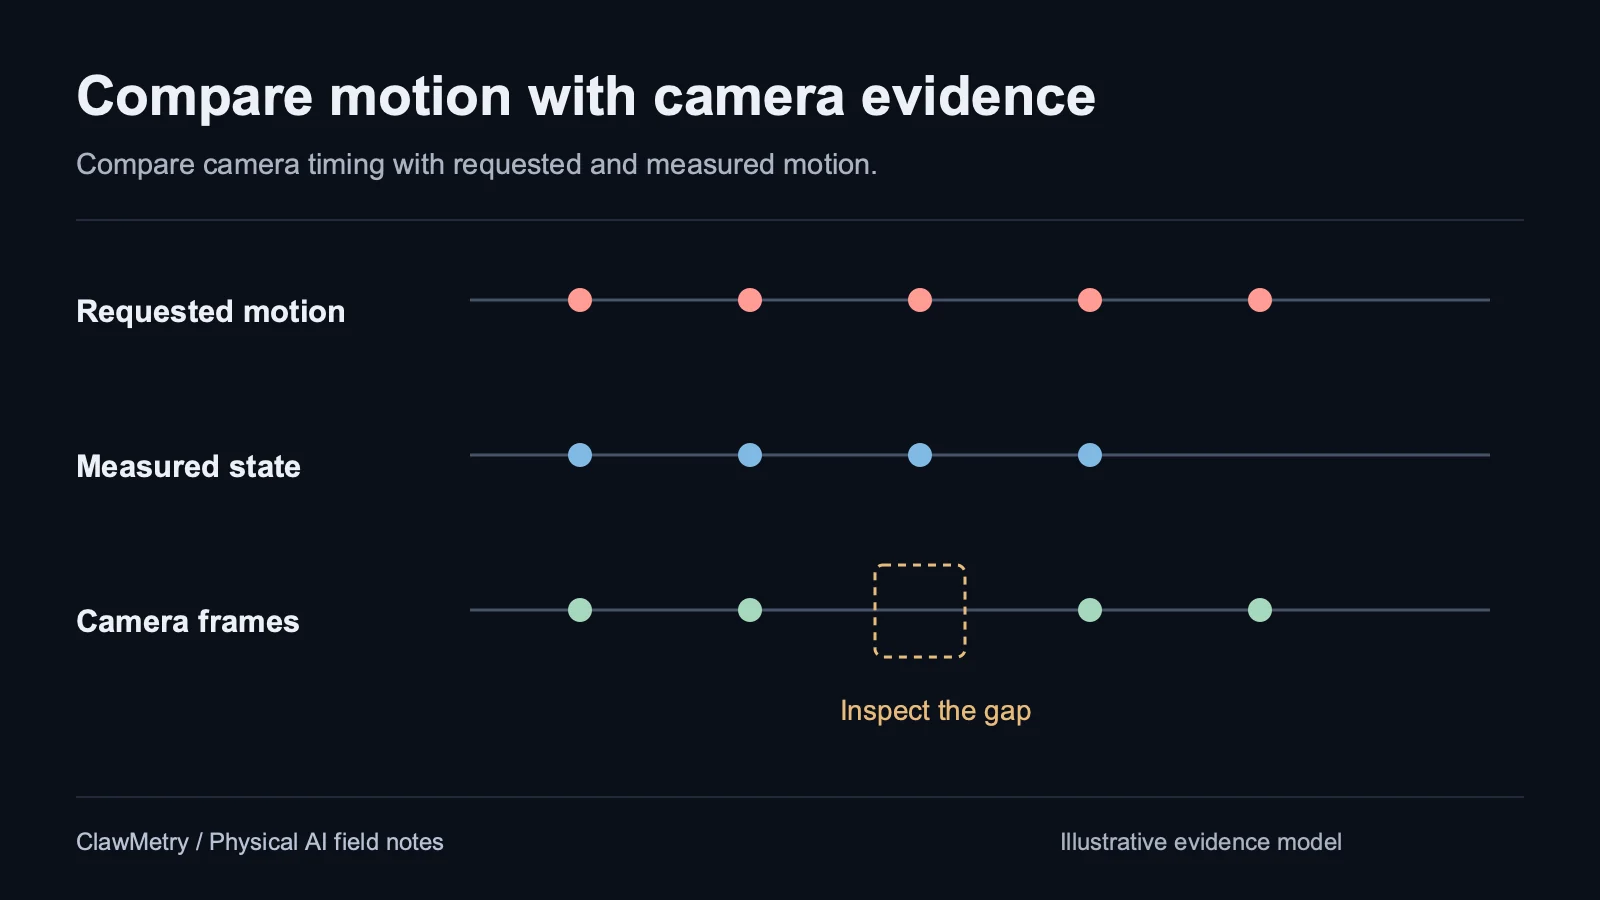
A step-by-step investigation method for camera freshness, state mismatches, recording gaps, and historical review.
Developer guide
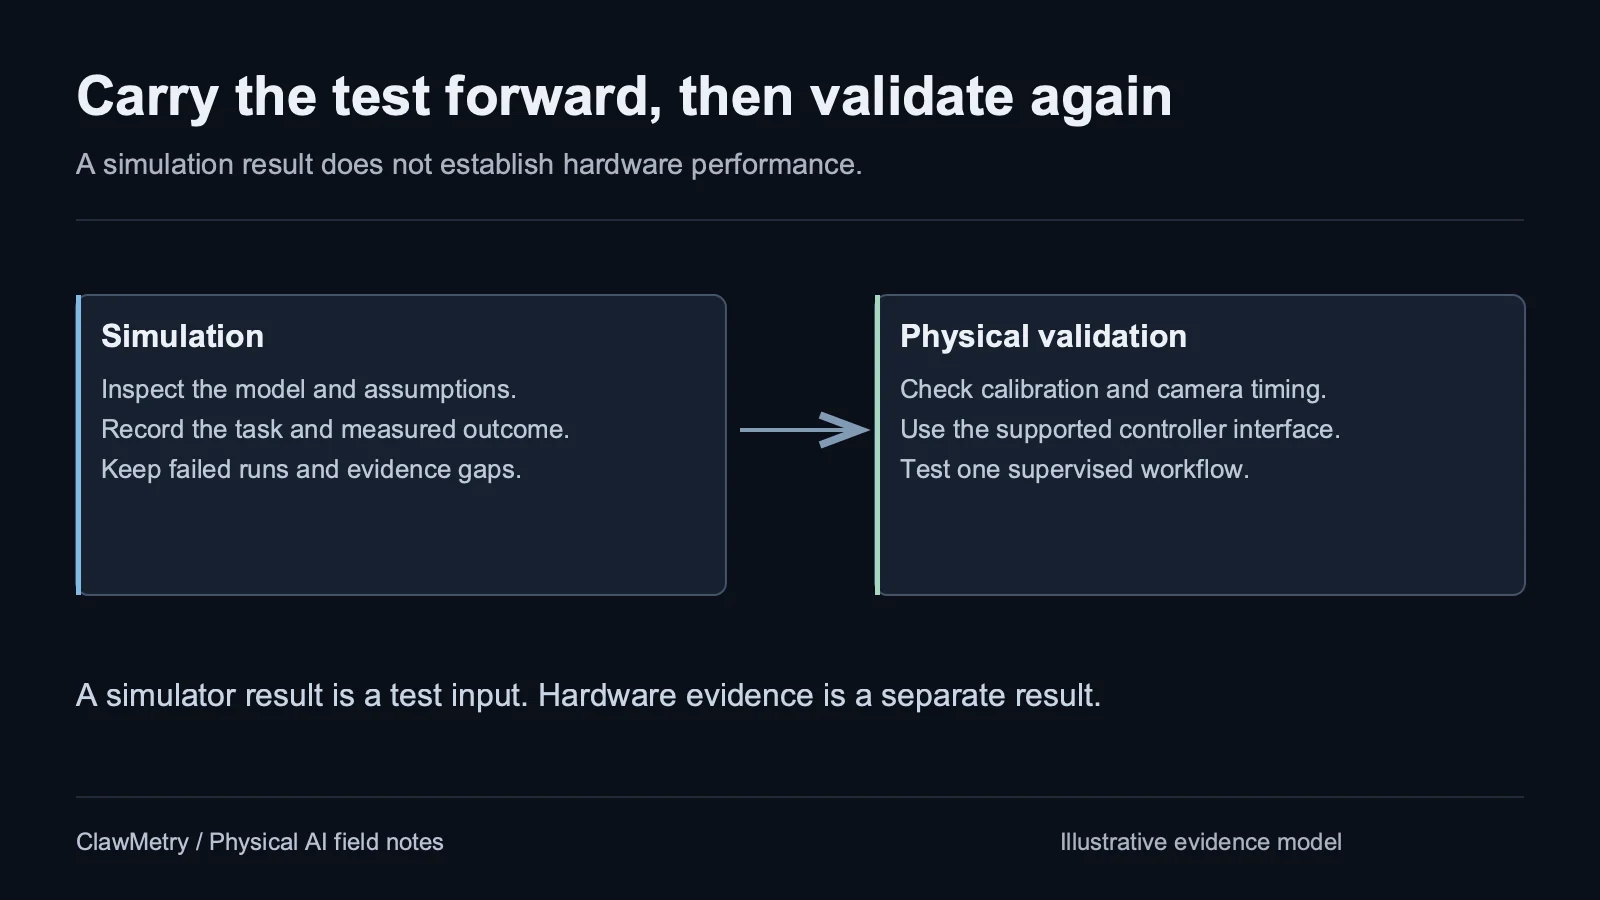
A practical path from an inspectable simulator record to one carefully documented hardware result.
Integration notes
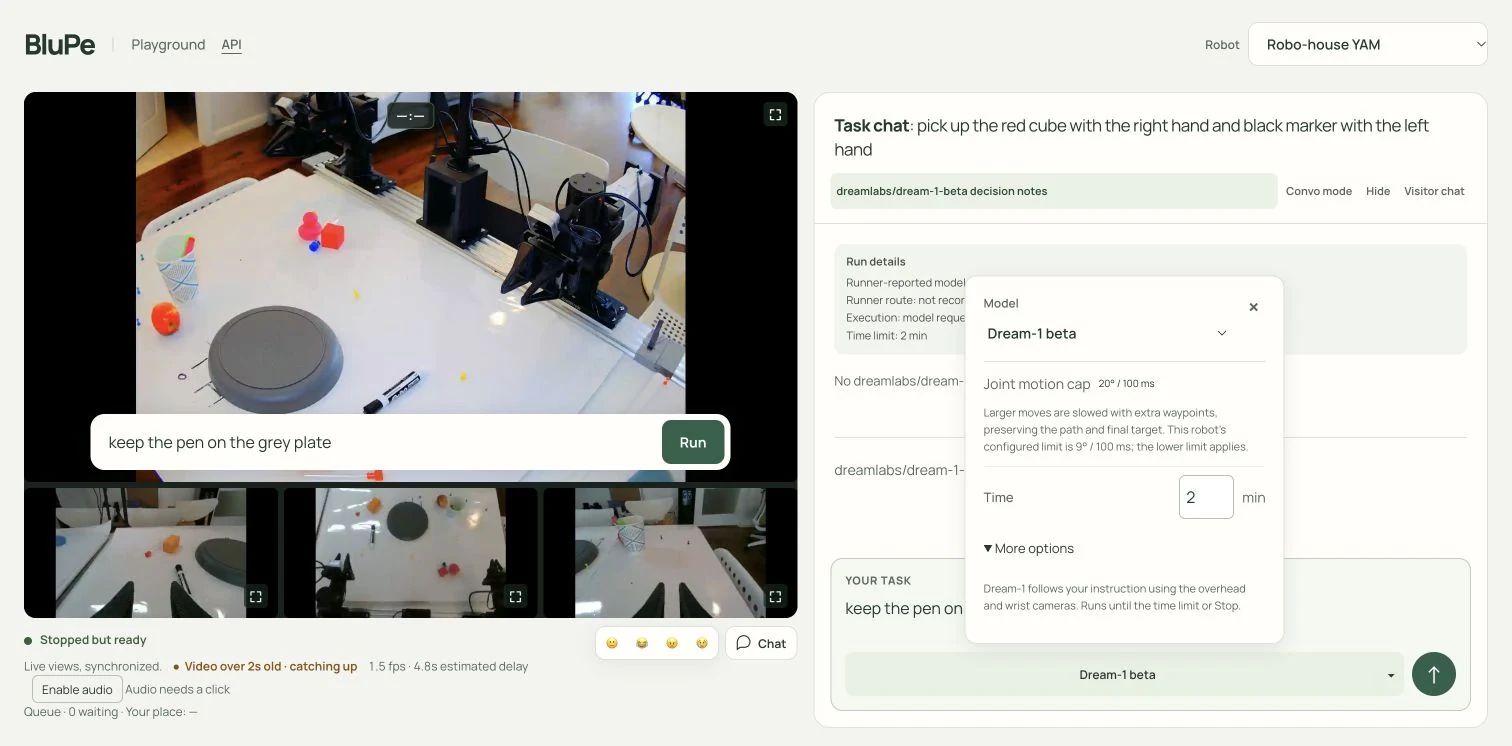
The early BluPe pilot, explained through its actual interface, recorded evidence, and an instructive warm-up failure.
Event preview
Confirmed selection and a concrete test plan for November 14 to 16. An event preview, with results to follow after the hackathon.
Research analysis
The primary report, its limits, and our interpretation of what evidence-led evaluation means for robot builders.
Foundations
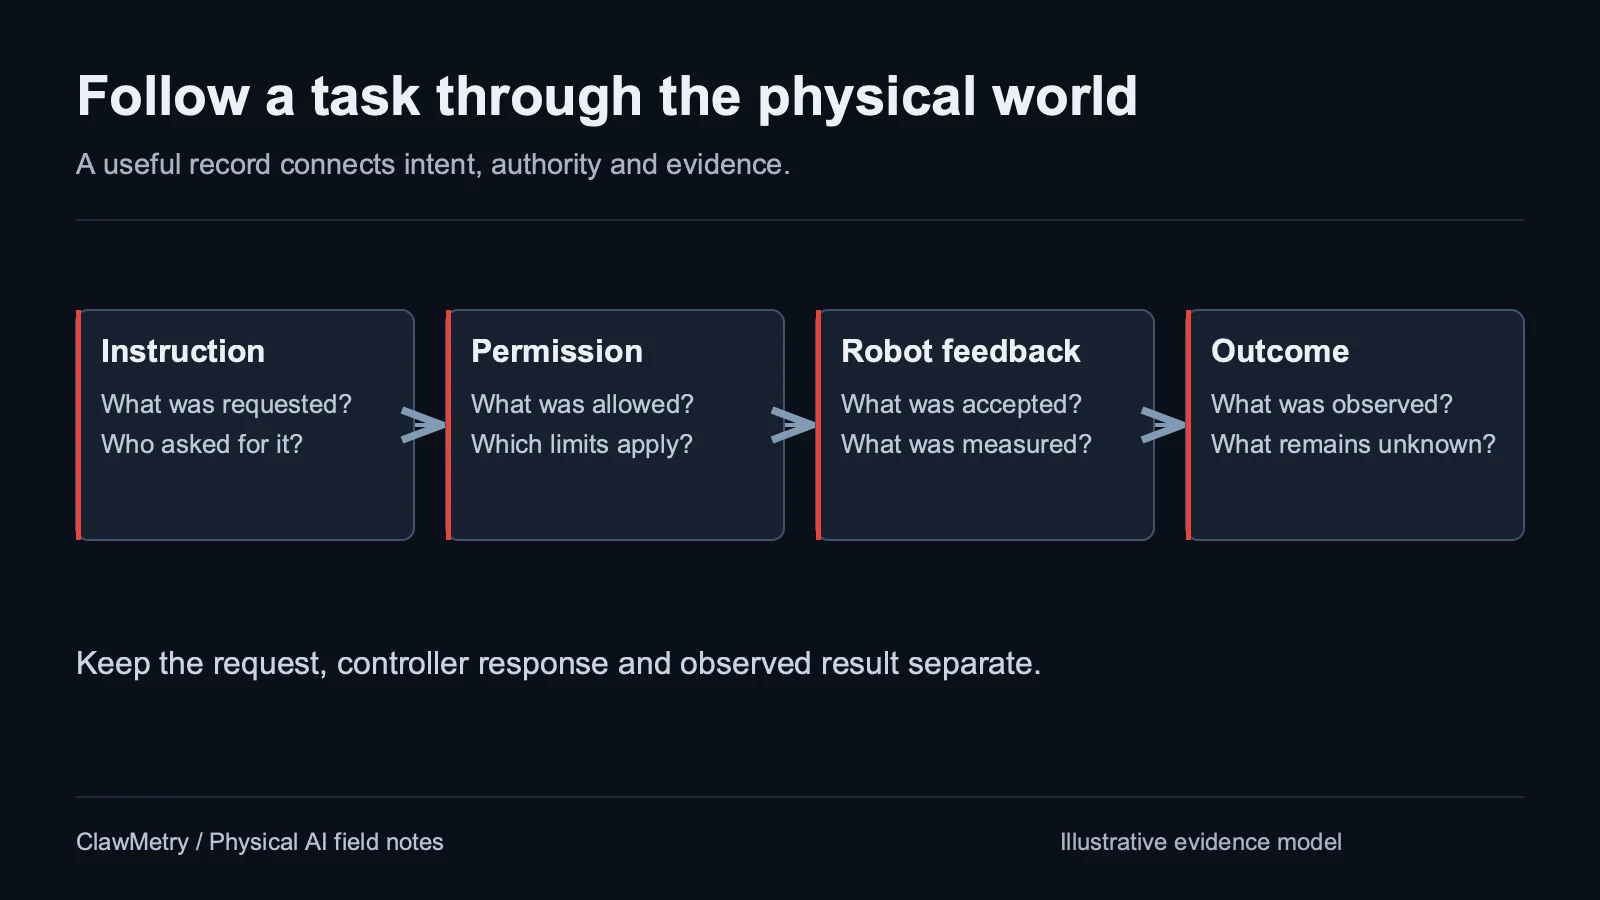
A clear introduction to the task, evidence, timing, and outcome questions behind robot observability.
Foundations
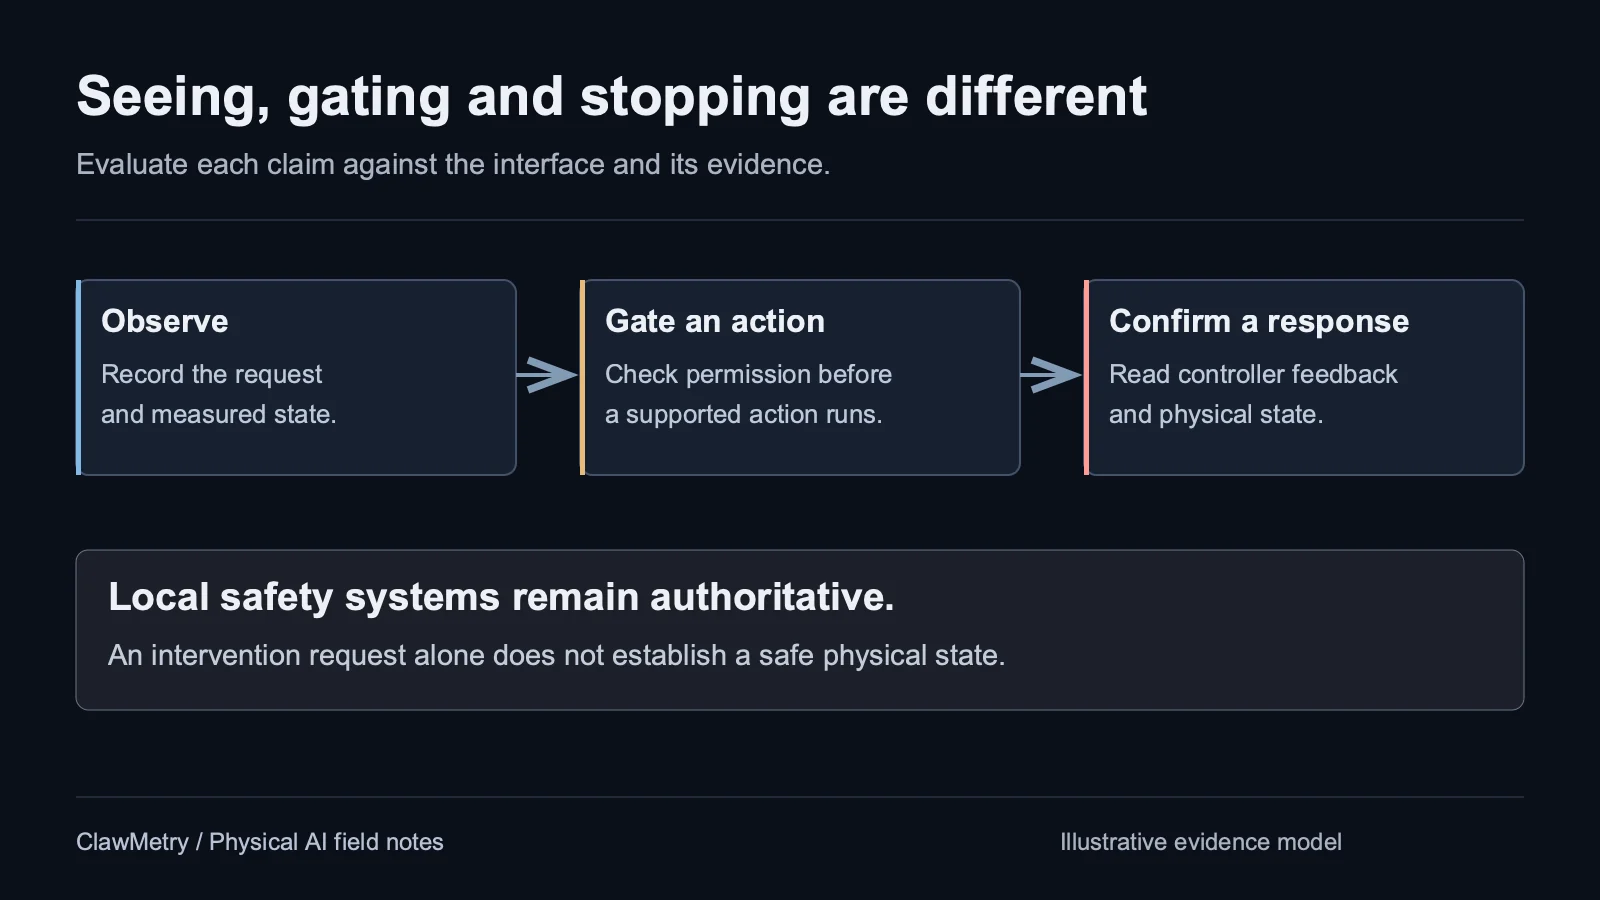
A vocabulary for evaluating robot guardrails, with clear boundaries between observation and an actual control response.
Each article distinguishes historical experiments, current integration work, proposed tests, and external research. Photographs, screenshots, organizer artwork and diagrams identify their sources and context.